Menu

XTAC UMI G1
XTAC UMI G1
XTAC UMI G1
XTAC UMI G1
XTAC UMI G1
XTAC UMI G1
XTAC UMI G1
XTAC UMI G1

XTAC UMI G1
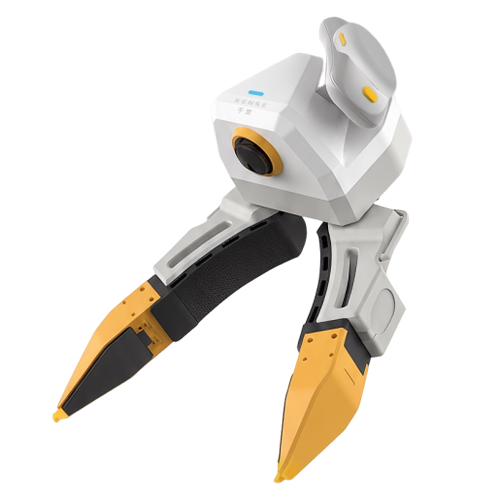
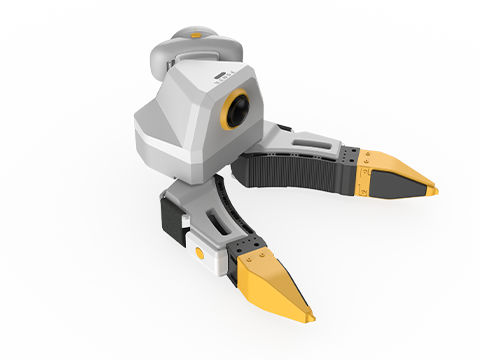
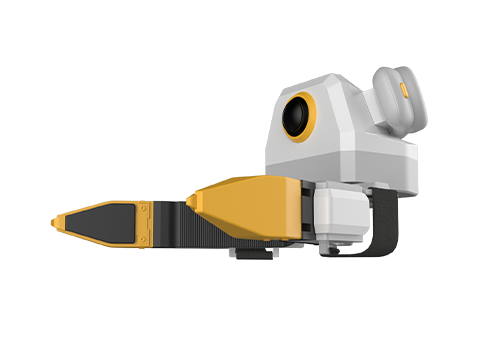
Xense XTac UMI G1 is a wearable data collection gripper designed for building embodied manipulation datasets. It integrates tricolor-light visual-tactile sensors, a wrist-mounted fisheye camera, and high-precision pose sensors to synchronously collect visual, tactile, pose, gripper-state, and IMU data. The system supports imitation learning, VLA / VTLA model training, and tactile world model research.

Short answer

XTAC UMI G1 is a product in the Wearable Visual-tactile Multimodal Data Acquisition Gripper category from Xense Robotics. Official overview: Xense XTac UMI G1 is a wearable data collection gripper designed for building embodied manipulation datasets. It integrates tricolor-light visual-tactile sensors, a wrist-mounted fisheye camera, and h. Highlights: Visual-tactile Fusionfor Real Interaction CaptureSynchronized visual capture | Precise contact-state perception | Complete interaction detail recording Tricolor. See the parameter table and related cases below. Pricing, lead time and customization options: [To be confirmed by business].

Product Highlights
1760599667440594.png

Visual-tactile Fusionfor Real Interaction Capture

Synchronized visual capture | Precise contact-state perception | Complete interaction detail recording Tricolor-light visual-tactile sensing enables every real operation to be captured reliably.


1782470287281096.png

High-Precision Pose & High-Quality Data

Clear structure | Time-synchronized data | Direct pose output | Model-validated The system continuously outputs high-quality manipulation data that is verifiable, reusable, and ready for training.

1782470303459444.png

Connected to Mainstream Ecosystems, Ready-to-Use Data Ecosystem-Compatible, Training-Ready Data

Supports LeRobot / MCAP data ecosystems, From data collection to model training, it enables a seamless workflow and lowers the barrier to data usage.


1782470313938119.png

Lightweight Integration for Multi-Scenario Deployment

Lightweight handheld unit | Backpack computing unit | Continuous Data Collection for Multi-Task and Multi-Scenario From lab environments to real-world applications, the data collection process becomes more natural and stable.

1782470325325616.png

Compliant Fingertip Design for Enhanced Fine Grasping

Easy pickup of small objects | Easy grasping of thin sheets | Better gripping of edge objects An innovative end structure enhances fine-grasping capability and adapts to more complex real-world operation scenarios.


1782470336195881.png

Biomimetic Dual-Finger Design for Natural Pinching

Human-like operation | More direct data collection | More stable control Designed around natural human pinching movements, it makes real interaction capture smoother and more precise.


Specifications

6.png

Gripper Type

Synchronization Accuracy

Two-finger structure

Multi-device time synchronization: 5 ms

Dimensions (L × W × H) (mm)

Trajectory Accuracy

145×186×170

Spatial positioning accuracy: < 3 mm

Weight – Master Gripper

Tactile Sensing Configuration

Approx. 370 g

2 × visuo-tactile sensors

Maximum Payload

IMU

2.5kg

9-axis, 200 Hz

Battery Life / Power

Tactile Sensor Frame Rate / Range

3-hour battery / 

AC power

120 FPS tricolor-light 

visuo-tactile sensing, 0–25 N

Opening Range / Angle

Tactile Sensor Data / Images

0–150 mm, 

-9° to +50°

Raw tactile data / 3D morphology data 

3D distributed force data / 6D resultant force data

Video Specifications

Output Data Types

Visual-tactile camera (max): 

 640 × 480 @ 120 FPS MJPEG 

Wrist camera (max): 

 1920 × 1080 @ 60 FPS MJPEG

RGB images, multimodal tactile information 

gripper opening angle, IMU data,  

spatial positioning trajectory

Storage

Communication Interface

Local and cloud storage

USB 2.0

Fisheye Lens Field of View (FOV)


190°


Product Video
Scan the QR code to Purchase

Scan the QR code to Purchase